

High speed without risks
Big Data and related technologies are demanding increasingly higher data rates. At the same time, electronic components must not only become faster and smarter, but also smaller. This results in specific risks in data transmission and, consequently, new challenges for connector technology. What should you look for in your connector to avoid signal interference?

The ongoing digitalization across all industries—such as the Industrial Internet of Things, Industry 4.0, Smart Grid, and Smart Home—requires high-speed data transmission from the sensor to the cloud. But this applies not only to sensors but also to industrial control systems and camera systems, datacom, and server applications: Signals must be reliably transmitted at 20 Gbit/s and higher. In addition to high speed, the IIoT, big data, and related technologies are driving another trend: electronic components must not only become faster and smarter, but also smaller and smaller. This ongoing miniaturization makes it more difficult for developers to pass the mandatory EMC tests required by the European directive. This is because electronic components within an assembly can act as both sources and sinks of interference, and the close proximity of sensitive components increases the risk of mutual interference.
Definition of “vehicle electrical system”: Decentralized, domain- and zone-based architecture

The classic decentralized architecture in automobiles consists of up to 100 ECUs (ECU), with each ECU assigned a specific function: engine control, airbag, ABS/ESP, seat adjustment, climate control, … Each ECU operates independently and communicates with other ECUs via gateways.
Over the past few decades, the decentralized architecture has undergone historical growth, with each new functionality requiring the addition of another ECU. Today, however, it is reaching its limits: Increasing functionality significantly raises the installation and wiring costs within the vehicle.
In domain-based architecture, the ECUs are grouped into different functional areas. Each domain is responsible for a specific area of the vehicle, such as powertrain, infotainment, or safety. The overarching control of a domain is handled by a standalone high-performance computer (HPC). This HPC coordinates the ECUs within its domain. For the safety functional area, for example, these would include ECUs for driver assistance systems, ABS/ESP, and steering systems.
Compared to decentralized architecture, the smaller number of installed ECUs reduces wiring and installation effort. The domain architecture can thus also effectively contribute to cost and weight reduction compared to decentralized architecture. Additionally, new functions can be integrated later with minimal effort.
In zone architecture (zonal architecture), the structure is not based on domains but on local zones. For example, multiple functionalities are bundled within a single zone in a vehicle. Accordingly, functions such as the powertrain and infotainment can certainly be combined and processed within a single zone controller. The various zone controller are managed by a central HPC. The advantage is clear: a reduction in the number of ECUs and their wiring by up to 50 percent.
Over the past few decades, the decentralized architecture has undergone historical growth, with each new functionality requiring the addition of another ECU. Today, however, it is reaching its limits: Increasing functionality significantly raises the installation and wiring costs within the vehicle.
In domain-based architecture, the ECUs are grouped into different functional areas. Each domain is responsible for a specific area of the vehicle, such as powertrain, infotainment, or safety. The overarching control of a domain is handled by a standalone high-performance computer (HPC). This HPC coordinates the ECUs within its domain. For the safety functional area, for example, these would include ECUs for driver assistance systems, ABS/ESP, and steering systems.
Compared to decentralized architecture, the smaller number of installed ECUs reduces wiring and installation effort. The domain architecture can thus also effectively contribute to cost and weight reduction compared to decentralized architecture. Additionally, new functions can be integrated later with minimal effort.
In zone architecture (zonal architecture), the structure is not based on domains but on local zones. For example, multiple functionalities are bundled within a single zone in a vehicle. Accordingly, functions such as the powertrain and infotainment can certainly be combined and processed within a single zone controller. The various zone controller are managed by a central HPC. The advantage is clear: a reduction in the number of ECUs and their wiring by up to 50 percent.
Requirements for the HPC and its connector

The resulting demands on an HPC are significant: Not least, the processing of imaging data in the infotainment sector or in camera systems for autonomous driving requires secure, high-speed data transmission with low latency. At the same time, signal transmission must not fail under any circumstances—its reliability must be guaranteed at all times.
High performance, fast, and above all, reliable data transmission—sometimes under adverse environmental conditions—are therefore also requirements placed on the installed connector.
The “readability” of a signal can be illustrated using what is known as an eye diagram. This indicates whether a transmitted signal can be unambiguously assigned to the digital states 1 or 0 in the receiver.
To do this, a signal travels through a defined transmission path, where it is recorded, superimposed, and displayed by an oscilloscope. In this way, all possible signal waveforms can be superimposed on top of one another. In theory, the transitions between logical states are infinitely steep, and the signal lines run exactly on top of one another. Due to external interference and internal disturbances affecting the signal pairs, the signal rise flattens out, and the amplitude changes. This results in the eye-shaped pattern that gives the diagram its name.
High performance, fast, and above all, reliable data transmission—sometimes under adverse environmental conditions—are therefore also requirements placed on the installed connector.
The “readability” of a signal can be illustrated using what is known as an eye diagram. This indicates whether a transmitted signal can be unambiguously assigned to the digital states 1 or 0 in the receiver.
To do this, a signal travels through a defined transmission path, where it is recorded, superimposed, and displayed by an oscilloscope. In this way, all possible signal waveforms can be superimposed on top of one another. In theory, the transitions between logical states are infinitely steep, and the signal lines run exactly on top of one another. Due to external interference and internal disturbances affecting the signal pairs, the signal rise flattens out, and the amplitude changes. This results in the eye-shaped pattern that gives the diagram its name.

In the center of the diagram, you can see what is known as the “eye mask.” It is not possible to clearly identify the signal in this area.
The two eye diagrams illustrate the effects of trace length and impedance using the example of the ept Colibri-connector in the 16+ Gbit/s and 10 Gbit/s versions. The example demonstrates how a significant improvement in signal integrity was achieved through the further development of the contact design (see Fig. XX). Thanks to a shorter cable length and 100 Ω impedance, the eye pattern of the 16+ Gbit/s Colibri variant is clearer than that of the previous 10 Gbit/s Colibri variant—the signal pairs can be unambiguously interpreted.
The two eye diagrams illustrate the effects of trace length and impedance using the example of the ept Colibri-connector in the 16+ Gbit/s and 10 Gbit/s versions. The example demonstrates how a significant improvement in signal integrity was achieved through the further development of the contact design (see Fig. XX). Thanks to a shorter cable length and 100 Ω impedance, the eye pattern of the 16+ Gbit/s Colibri variant is clearer than that of the previous 10 Gbit/s Colibri variant—the signal pairs can be unambiguously interpreted.
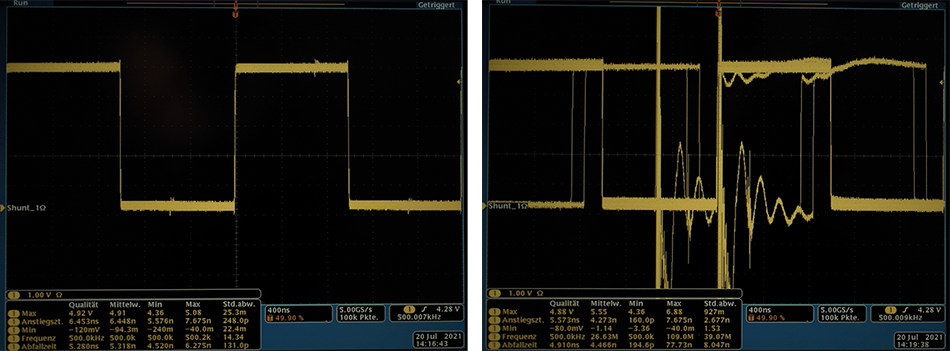
Since high-speed signals are particularly susceptible to electromagnetic interference, they require special signal protection. A connector can act as both a source of interference and a sink. For this reason, signal protection using a shield plate is recommended to shield the sensitive signals from external influences.
Figure 4 illustrates that even a small electrical pulse can distort the useful signal. The receiver can no longer unambiguously interpret the digital states of the HDMI signal after even a brief burst pulse of 0.5 kV, whereas the signal transmission via the shielded connector remains stable even at 4.4 kV.
Figure 4 illustrates that even a small electrical pulse can distort the useful signal. The receiver can no longer unambiguously interpret the digital states of the HDMI signal after even a brief burst pulse of 0.5 kV, whereas the signal transmission via the shielded connector remains stable even at 4.4 kV.

Using the coupling inductance (mutual inductance, LK) as an EMC parameter, the connector can be described by analyzing the electrical conditions in both functions—source and sink. The unit Henry is used for this purpose. This applies to both immunity (immunity) and emissions (electromagnetic emission). If the induced voltage (Uind), the generator voltage (UGen), and the generator constant (kGen) are known, the specific maximum permissible coupling inductance (L) for a given application can be determined using the following formula:
LK = Uind / (UGen * kGen)
The coupling inductance (mutual inductance) also helps the user select the appropriate connector (connector) in terms of its electromagnetic compatibility and avoid costly and time-consuming trial-and-error testing in the EMC-Labor. Here is an example: For an HDMI signal, a case-specific maximum mutual inductance of 47 picohenry (pH) was determined at a voltage of 4.4 kV. If the value exceeds this, the signal can no longer be transmitted without interference.
LK = Uind / (UGen * kGen)
The coupling inductance (mutual inductance) also helps the user select the appropriate connector (connector) in terms of its electromagnetic compatibility and avoid costly and time-consuming trial-and-error testing in the EMC-Labor. Here is an example: For an HDMI signal, a case-specific maximum mutual inductance of 47 picohenry (pH) was determined at a voltage of 4.4 kV. If the value exceeds this, the signal can no longer be transmitted without interference.
However, it is not only electromagnetic interference that jeopardizes the transmission of high-speed signals. Especially in automotive applications, connectors are repeatedly exposed to extreme environmental conditions such as vibration and shock. To ensure uninterrupted signal transmission even in harsh environments, the connector must be particularly robust. In this context, contact design, contact system, and termination technology play a decisive role.
Contact system as an influencing factor

Traditional two-part “ connector ” consist of a “Messer-” and a “ female contact.” However, in the event of a strong shock, the “ Male ” can detach from the “ Female.” To prevent such a “ discontinuity,” a double-sided “ Female ” can be used to ensure redundancy and thus reliable contact, as the second spring ensures that signal transmission is maintained at all times via at least one contact point (Fig. 5).

connector with a so-called “hermaphroditic” contact system, on the other hand, are even more robust. Their distinctive feature lies in the identical contact geometries of the connector pairs—Plug and Socket. Both therefore feature both a spring and a blade. This ensures that each pin is contacted by two springs, with the Plug and Socket interlocked so they cannot separate from one another. While a double-sided Female always ensures at least one contact point under mechanical stress, the interlocked geometries in gender-neutral contact systems guarantee that signal transmission always occurs via two contact points. This high level of redundancy thus enables maximum contact reliability (Fig. 5).

Surface-mount technology (SMT, solder paste) is recommended as the connection method (termination technology) for a durable connection between the printed circuit board and the connector. Using solder paste, the connectors are soldered to defined lands on the printed circuit board—the solder pads. Only in a so-called reflow oven is the solder melted and then allowed to harden. SMT enables the creation of stable connections between the connector and the printed circuit board. However, several criteria must be met for this: First, to ensure a solder joint that complies with the IPC-A-610 standard, the correct ratio of SMT lead, solder pad, and solder paste must be maintained. Only in this way can a high-quality connection be established that meets IPC Class 3 standards, making it suitable for use in high-performance electronics. Failures in signal transmission must be ruled out at all times in this class. An optimal solder connection can be recognized by the uniform formation of the meniscus. The contact must be completely surrounded by the solder meniscus to achieve the best retention forces on the printed circuit board. (Fig. 9).
The coplanarity of the contact pads is essential for an excellent connection, and this is verified through a 100% automated inspection during the manufacturing process.
Conclusion

Current developments in the automotive industry are constantly placing new demands on the connectors (connector) used in vehicles. At first glance, the role of these connectors seems to be fading into the background due to the reduced number of ECUs. Upon closer inspection, however, it becomes clear that their role is actually gaining importance precisely because of this shift toward central data processing via HPC: reliability in signal transmission has never been more important than it is today.